CEOE PhD Student Seminar Series Pt. 3

Department of Civil, Environmental and Ocean Engineering
Location: Pierce Hall, Room 216
Speakers: Pouya Darestani Farahani, Ocean Engineering PhD Student
Saaed Talamkhani, Civil Engineering PhD Student
ABSTRACT
Role of Antecedent Beach Morphology in Hurricane Impact Response by Pouya Darestani Farahani - Post-storm coastal impact is commonly characterized with qualitative scales, such as the Clark scale used by the Florida Department of Environmental Protection and the storm report classifications used in New Jersey. These depend on observer judgment, which limits reproducibility and obscures the physical processes behind the response. Erosional outcomes are shaped by both offshore forcing and antecedent morphological characteristics. Hurricane Idalia (August 2023) offers a natural experiment: erosional outcomes ranged from no detectable change to severe loss (Clark scale 0 to IV) at 114 profiles across Pinellas County despite near uniform storm forcing across 34 km of coastline. Comparing pre-storm profile characteristics with these outcomes revealed that morphology, rather than forcing, explains this divergence. Using pre- and post-storm surveys, a categorical morphological impact response framework is introduced to characterize response types along a severity spectrum for barrier and dune configurations. For dune profiles, subaerial beach volume was the strongest predictor of response severity, marking a threshold beyond which profiles transition to more severe responses. Average beach slope and foredune slope were also significant, and a similar pattern held for barrier profiles, where beach slope and crest distance were the strongest predictors. A small set of measurable pre storm indicators can therefore predict hurricane impact severity, and profile configuration and response characterization should both be considered in coastal vulnerability assessment.
Advanced Underwater Vision-Based Robotics for Automated Infrastructure Inspection and Maintenance by Saeed Talamkhani - Overwater bridges play a pivotal role in civil infrastructure systems. In the U.S., nearly 15% of approximately 500,000 bridges over waterways have underwater components rated as structurally deficient. Currently, underwater inspection and maintenance are predominantly diver-based, which is costly, time-consuming, and hazardous. Recent advances in computer vision and robotics offer unprecedented opportunities to automate these tasks safely and cost-effectively. However, vision-based robotic systems are limited in analyzing underwater inspection images, which suffer from haziness, color distortion, and low visibility caused by light scattering, light attenuation, and low-light conditions. To address this limitation, this seminar presents an underwater vision-enhanced image segmentation method that integrates quality enhancement and semantic segmentation. The method extracts depth, illumination, and color feature maps, analyzes them through a multi-stream, quality-aware encoder, and fuses the enhanced representations in a decoder to localize bridge components, achieved a mean intersection over union (IoU) of 91.7%, outperforming state-of-the-art segmentation methods. This research lays a foundational pathway toward vision-based autonomous underwater inspection.
BIOGRAPHY
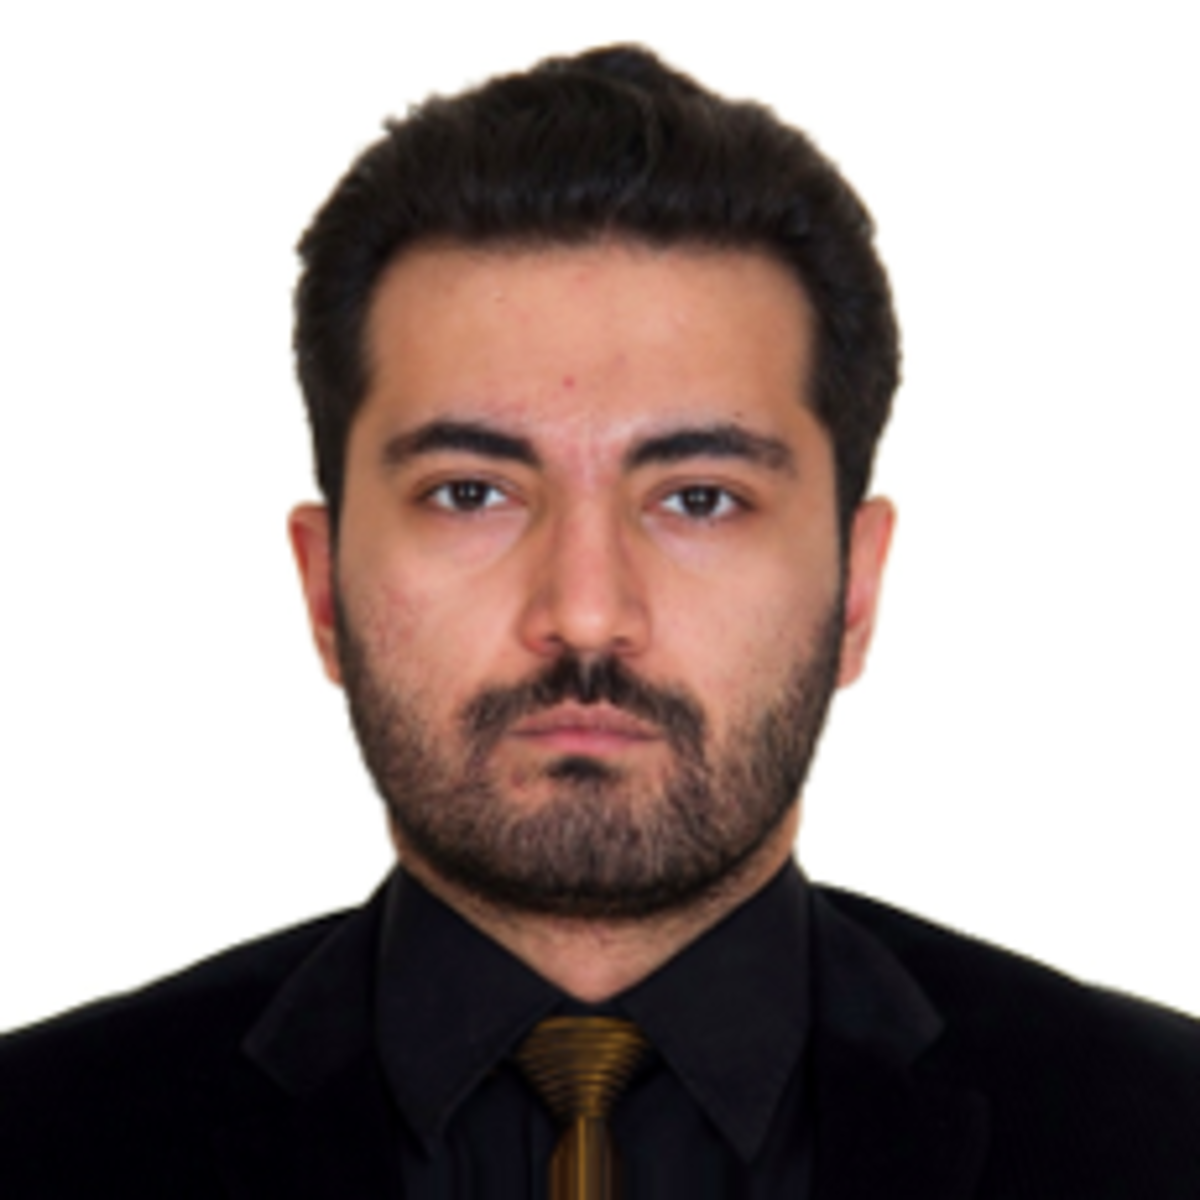
Pouya Darestani Farahani is a PhD student in Ocean Engineering at Stevens Institute of Technology, where his research focuses on coastal storm impacts, beach and dune morphodynamics, and coastal risk assessment. He is working under the supervision of Dr. Jon K. Miller and Dr. Matthew S. Janssen. His doctoral research investigates how pre-storm beach morphology controls the storm impact severity, the mechanisms that drive transitions between impact responses, and the consequences on the upland area, with the goal of developing generalized quantitative frameworks for storm impact response classification.
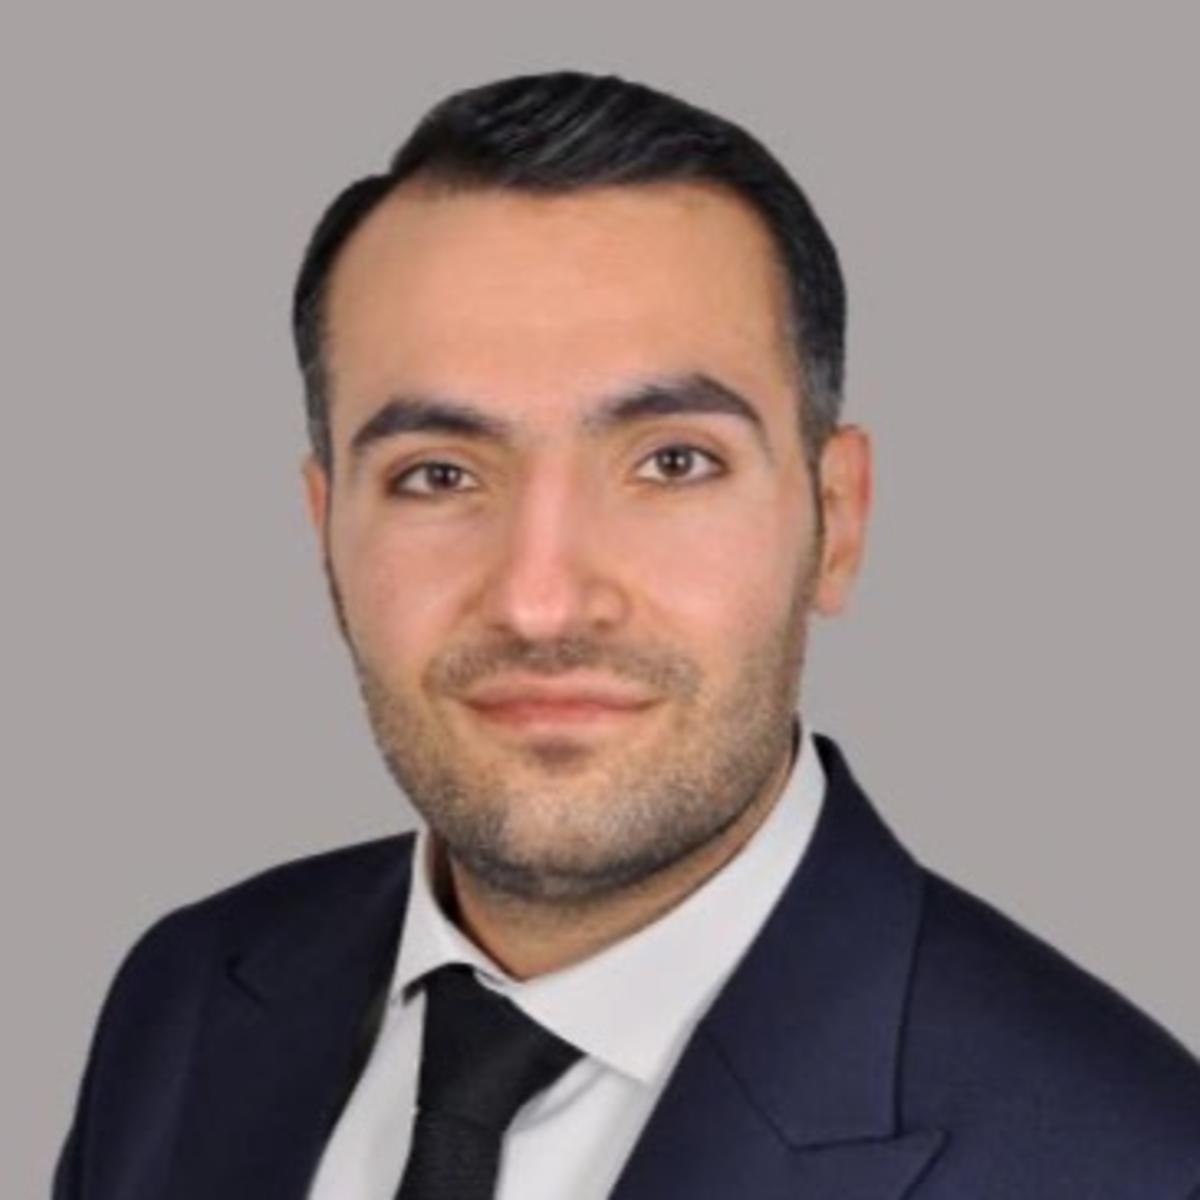
Saeed Talamkhani is a PhD student in Civil Engineering at Stevens Institute of Technology, advised by Prof. Kaijian Liu. His research integrates artificial intelligence, computer vision, and semantic modeling to enable underwater robots for automated inspection and maintenance of civil infrastructure. His work has been published in Automation in Construction and presented at ASCE i3CE 2024 and 2025 and IConIC 2026, where he received the Best Paper Award (Runner-up). He holds MS and BS degrees in Civil Engineering from Imam Khomeini International University and the University of Qom, Iran.
Discrimination notice: Persons of all identities are invited to and included in this group. Stevens does not discriminate against any person on the basis of sex, race, religion, disability, sexual orientation, gender expression, or any other basis prohibited by law.
Photo and video notice: At any time, photography or videography may be occurring on Stevens’ campus. Resulting footage may include the image or likeness of event attendees. Such footage is Stevens’ property and may be used for Stevens’ commercial and/or noncommercial purposes. By registering for and/or attending this event, you consent and waive any claim against Stevens related to such use in any media. See Stevens' Privacy Policy for more information.